Some ideas are worth returning to.
Papers that changed the questions—and the methods.
From models to the world.
Follow methods across domains—and the limits of their evidence.
From understanding to action
Multimodal knowledge enters robotics while perception and control develop along their own paths.
From reasoning to driving
How do general models and driving-specific task stacks meet at action?
From generation to worlds
The next frame, a possible future, or an environment for decisions?
Back to the source.
← Swipe to browse research institutions →
MODELS & GENERAL INTELLIGENCE
OpenAI
Reasoning · Open weights · Alignment
Anthropic
Interpretability · Alignment · Safety
Google DeepMind
Gemini · Science · Robotics
xAI
Grok · Model releases · Research
Alibaba Qwen
Open models · Multimodality · Agents
DeepSeek
Reasoning · MoE · Efficient training
Moonshot AI · Kimi
Multimodal · Reasoning · Agents
Meta AI · FAIR
Vision · Representation · Open research
Mistral AI
Mixture-of-experts · Efficiency · Reasoning
ROBOTICS, DRIVING & WORLD MODELS
Unitree
Multimodal · Humanoids · Manipulation
Deep Robotics
Locomotion · Perception · Control
Waymo
Multimodal · Driving · Planning
Wayve
Driving · World models · Generation
NVIDIA
World models · Simulation · Robotics
Physical Intelligence
Vision-language-action · Manipulation
Huawei Intelligent Automotive
Autonomous systems · World-action models · Sensors
XPeng AI
World models · Driving · Simulation
Baidu Apollo
Perception · Driving datasets · Multi-task learning
Countries and regions follow institutional sources; cross-border work stays visible.
Global research map
Follow institutional geography to explore how research in models, robotics and autonomous driving connects across regions.
Open the map ↗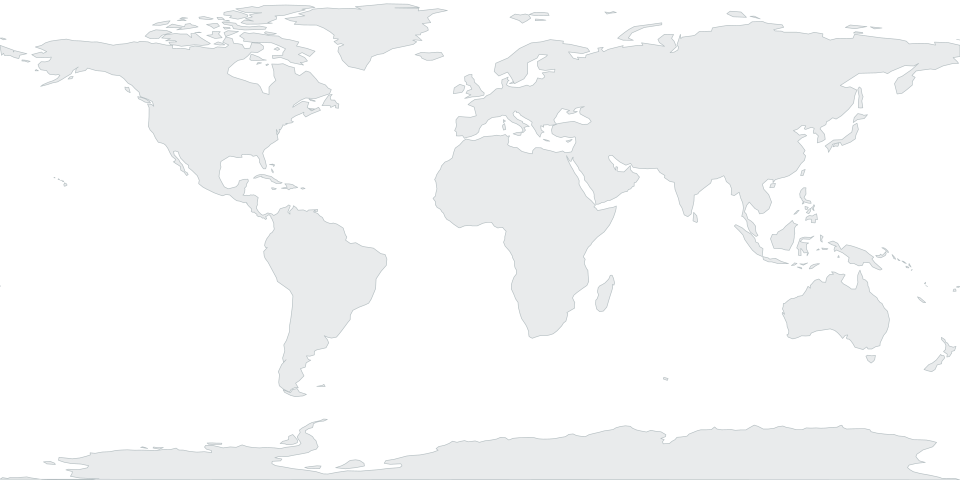
Follow the questions.
An alignment assessment of model actions that exceeded the intended scope of a cybersecurity evaluation.
A research overview of distributed agents linking large biological datasets with scientific literature. Proposed connections still require experimental follow-up.
Official research discussion of improving coding capabilities in languages with less available training material.
Models assess their own conversations as an additional misuse-detection layer, reusing cached context to limit overhead.
Official model documentation covering evaluation, limitations and safety considerations. The date records the listed model-card update.
Fuses LiDAR point clouds and proprioception through attention, connecting terrain perception with a reinforcement-learned quadruped policy.
A report of unintended actions observed during model evaluation and internal use, with discussion of safeguards.
An official account of progress in computer-use agents. Read the original methods and evaluations separately from deployment claims.
An unexplored corner, for now.
Try another keyword or clear the filters.
Translations and notes are reading aids. Follow the original work for the full argument.
How we arrived here.
Language, perception, robotics, driving and world models.
DeepSeek-R1: Incentivizing Reasoning Capability in LLMs via Reinforcement Learning
Reinforcement learning is used to develop reasoning behavior, with additional pipelines for usable models and distillation.
Browse the monthly chronology
10 research records
From Anthropic, OpenAI, Google, Deep Robotics, academic researchers. Grouped by the source publication date; document types are identified separately.
Stay curious.
Keep the questions open.
Foundational ideas beside new work. One question leading to the next reading.